Skip to content

A Learnable Sparse Attention Graph Architecture for Heterogeneous Multi-UAV Air-to-Ground Mission Planning

Sep 2026 · Drones · 0 citations · 45 references
UAV Applications and Optimization

TL;DR

This study provides an innovative and effective method for mission planning of heterogeneous multi-UAV systems in partially observable adversarial environments and outperforms the best-performing baseline algorithm by more than 20% across all operational performance metrics.

Abstract

In the complex problem of air-to-ground mission planning, multi-UAV systems face significant challenges such as system complexity and heterogeneity, insufficient target observability, and difficulties in collaborating information sharing. To address these issues, this paper proposes a novel learnable sparse attention graph architecture (SAGA). This architecture deeply integrates graph reasoning and policy optimization within the MAPPO framework and includes three innovative mechanisms: (i) a GATv2-based graph neural network encoder that performs multi-round distributed consensus on the communication graph among UAVs via a multi-head attention mechanism, enabling selective aggregation of tactical information; (ii) an edge predictor that learns to prune low-value communication links, generating a sparse and mission-adaptive communication topology; and (iii) an L1 sparsity penalty term that further enhances communication efficiency. In a self-developed simulation environment for heterogeneous multi-UAV mission planning, comprehensive comparative experiments were conducted against the following baseline reinforcement learning algorithms: MADDPG, MATD3, QMIX, MAPPO, TarMAC, DGN, and G2ANet. The experimental results show that SAGA achieves reward values of 390 and 1100 in small-scale and large-scale scenarios, and outperforms the best-performing baseline algorithm by more than 20% across all operational performance metrics. Generalization experiments validate the model’s robust transfer capability under unknown defense deployment modes. Ablation experiments further confirmed the individual contributions of the three components. This study provides an innovative and effective method for mission planning of heterogeneous multi-UAV systems in partially observable adversarial environments.

Read PDF

Similar papers

Sep 2026

A Multi-UAV Cooperative Navigation Method Based on Policy Decomposition Structure

Simulation results demonstrate that, compared to traditional methods, GS-MADDPG improves the navigation success rate, robustness, and generalization performance, and verifies its effectiveness in multi-UAV cooperative navigation for search and rescue tasks.

Li Tan, Hai-Xia Zhao, Jia-Qin Chai et al. · 0 citations
Open access Oct 2026

AGI-inspired UAV Cluster Communication Self-Organization Framework: Multi-Agent Learning and Network Optimization

Artificial General Intelligence-inspired Multi-Agent Knowledge Transfer (AGI-MAKT) is presented, a novel self-organizing framework for UAV cluster communication networks capable of self-organization and adaptation in complex, resource-constrained environments with limited human supervision.

Fan Zhou · 0 citations
Conference Aug 2026

Graph Convolutional Multi-Agent Reinforcement Learning for Cooperative UAV Swarm Navigation

Cooperative navigation of unmanned aerial vehicle (UAV) swarms in obstacle-rich environments requires simultaneous goal reaching, collision avoidance, and decentralized coordination. This paper presents a graph convolutional network-based multi-agent reinforcement learning (GCN-MARL) framework that explicitly represent...

Yu-Cheng Lin, Hua Zheng · 0 citations
Open access Sep 2026

An Asymmetric Dual-Graph Actor–Critic for Scheduling Heterogeneous Directed-Energy Systems in Counter-UAV Defense

Coordinated swarms of low-cost commercial unmanned aerial vehicles (UAVs) pose a growing security threat to civil infrastructure, public events, and restricted airspace. Effective counter-UAV defense requires the real-time, cooperative scheduling of heterogeneous directed-energy systems, where high-energy lasers provid...

Jia-Jin Li, Ya-Li Yang, Sheng-Kai Yan et al. · 0 citations
#artificial intelligence Preprint Oct 2026

Shared-Roadmap Generation and Evaluator for Multi-Agent Path Planning Using Heterogeneous Graph Neural Network

Multi-agent path planning (MAPP) in continuous environments often relies on roadmaps to balance safety and search efficiency. However, traditional roadmap generation methods, such as lattice grids or standard sampling-based approaches, frequently face a trade-off between graph density and the likelihood of finding feas...

Brandon Ho, Nikola Rogers, Seung-Kyum Choi · 0 citations
Open access Sep 2026

Collaborative Computation and Migration in Multi-UAV Networks with Semantic Communication

A Heterogeneous Graph Attention Network-based Multi-Agent Twin Delayed Deep Deterministic Policy Gradient (HAN-MATD3) algorithm that uses a heterogeneous graph to model the network topology and apply HAN to extract important semantic features is developed to support joint optimization.

Bin Li, Yu-Chen Ou, Yin-Qiu Liu et al. · 0 citations

Related blog posts

Microsoft Research Blog Jul 13, 2026

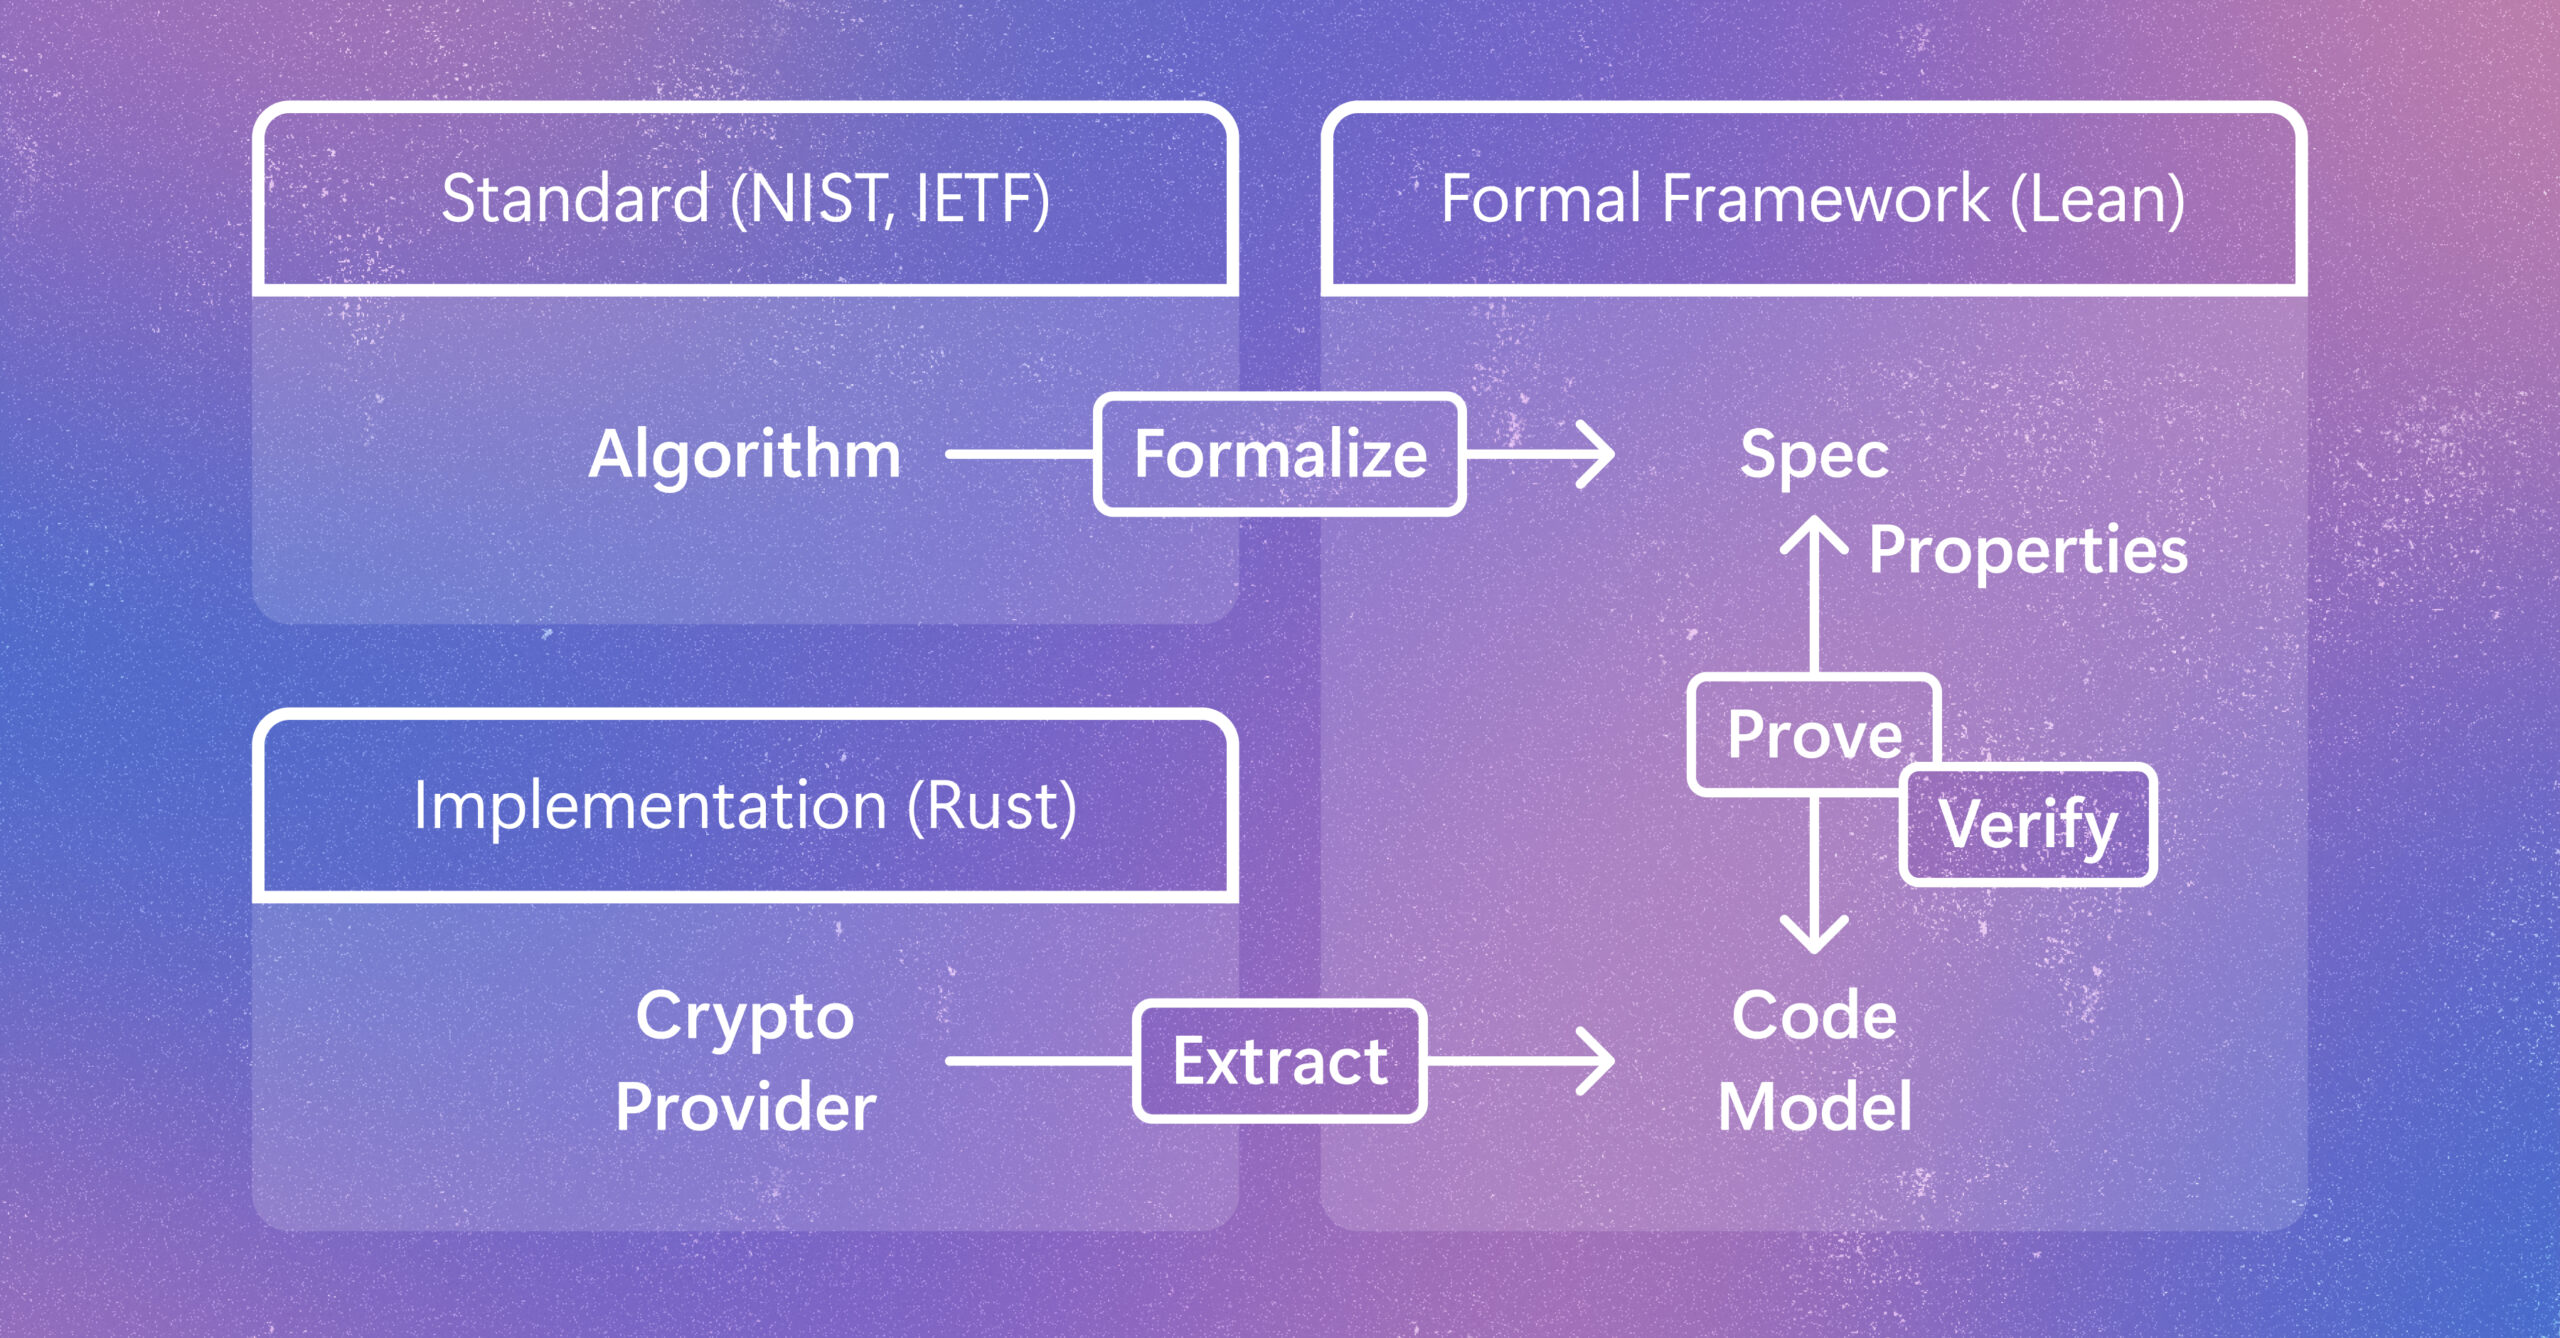
Verifying Rust cryptography in SymCrypt, from standards to code

Cryptographic code supports vital protections in modern computing systems. Learn how a new method helps verify code as developers write it while preserving speed and adaptability as it gets implemented and evolves. The post Verifying Rust cryptography in SymCrypt, from standards to code appeared first on Microsoft Research.

We use cookies to run the site and, with your consent, for analytics and to show ads. See our Cookie Policy.
