Multi-robot systems that combine the complementary capabilities of specialised platforms are critical for complex missions in challenging, inaccessible environments. Current deployments assign an operator or operator team to each robot, with collaboration relying on operator-to-operator communication to manually coordinate heterogeneous platforms with incompatible interfaces. This operator-dependent approach increases cognitive load and limits scalability across robots from different manufacturers. This study designs and evaluates a shared-visualisation collaborative teleoperation interface to improve operator coordination, situational awareness, and the task performance in multi-operator, multi-robot systems. A comparative user study with 16 participants compared three teleoperation conditions: co-located operators with a shared interface, remote operators with a shared interface, and co-located operators with individual interfaces. Participants controlled two simulated robots in a nuclear power plant digital twin to complete disaster response tasks. Performance metrics, physiological data, and behavioural measures were recorded to assess task performance, cognitive load, and operator awareness across conditions. The co-located shared-interface condition achieved the fastest mission completion (292.8 s), outperforming remote operation (351.6 s) and individual interfaces (385.1 s), with the fewest collisions (0.9 per trial) and highest situational awareness accuracy (91.1 %). Physical co-presence was associated with reduced cognitive load, with NASA-TLX scores increasing from 38.2 in co-located to 57.7 in remote operation, supported by consistent physiological indicators. These results demonstrate that co-presence and shared interfaces provide complementary benefits, supporting workload regulation and mutual awareness respectively in multi-operator, multi-robot teleoperation.

This paper investigates developing real-world perception for active agents, proposes Gibson Environment for this purpose, and showcases a set of perceptual tasks learned therein.
F. Xia, Amir Zamir, Zhi-Yang He et al.· 2018 IEEE/CVF Conference on...· 1,069 citations· ⚡112
This publication proposes a definition and a classification of agile software development approaches and analyses ten software development methods that can be characterized as being "agile" against the defined criterion.
P. Abrahamsson, O. Salo, Jussi Ronkainen et al.· arXiv.org· 727 citations· ⚡54
The study shows that agile practices improve both informal and formal communication, but indicates that, in larger development situations involving multiple external stakeholders, a mismatch of adequate communication mechanisms can sometimes even hinder the communication.
M. Pikkarainen, Jukka Haikara, O. Salo et al.· Empirical Software Engineeri...· 401 citations· ⚡48
The results indicate that software engineering work practices are chosen opportunistically, adapted and configured to provide value under the constrains imposed by the startup context.
Nicolò Paternoster, Carmine Giardino, M. Unterkalmsteiner et al.· Information and Software Tec...· 394 citations· ⚡54
Professor Paris Smaragdis develops computers with superhuman hearing for applications like speech recognition, music understanding, and environmental monitoring.
MIT News · Artificial Intelligence· news.mit.eduOct 23, 2026
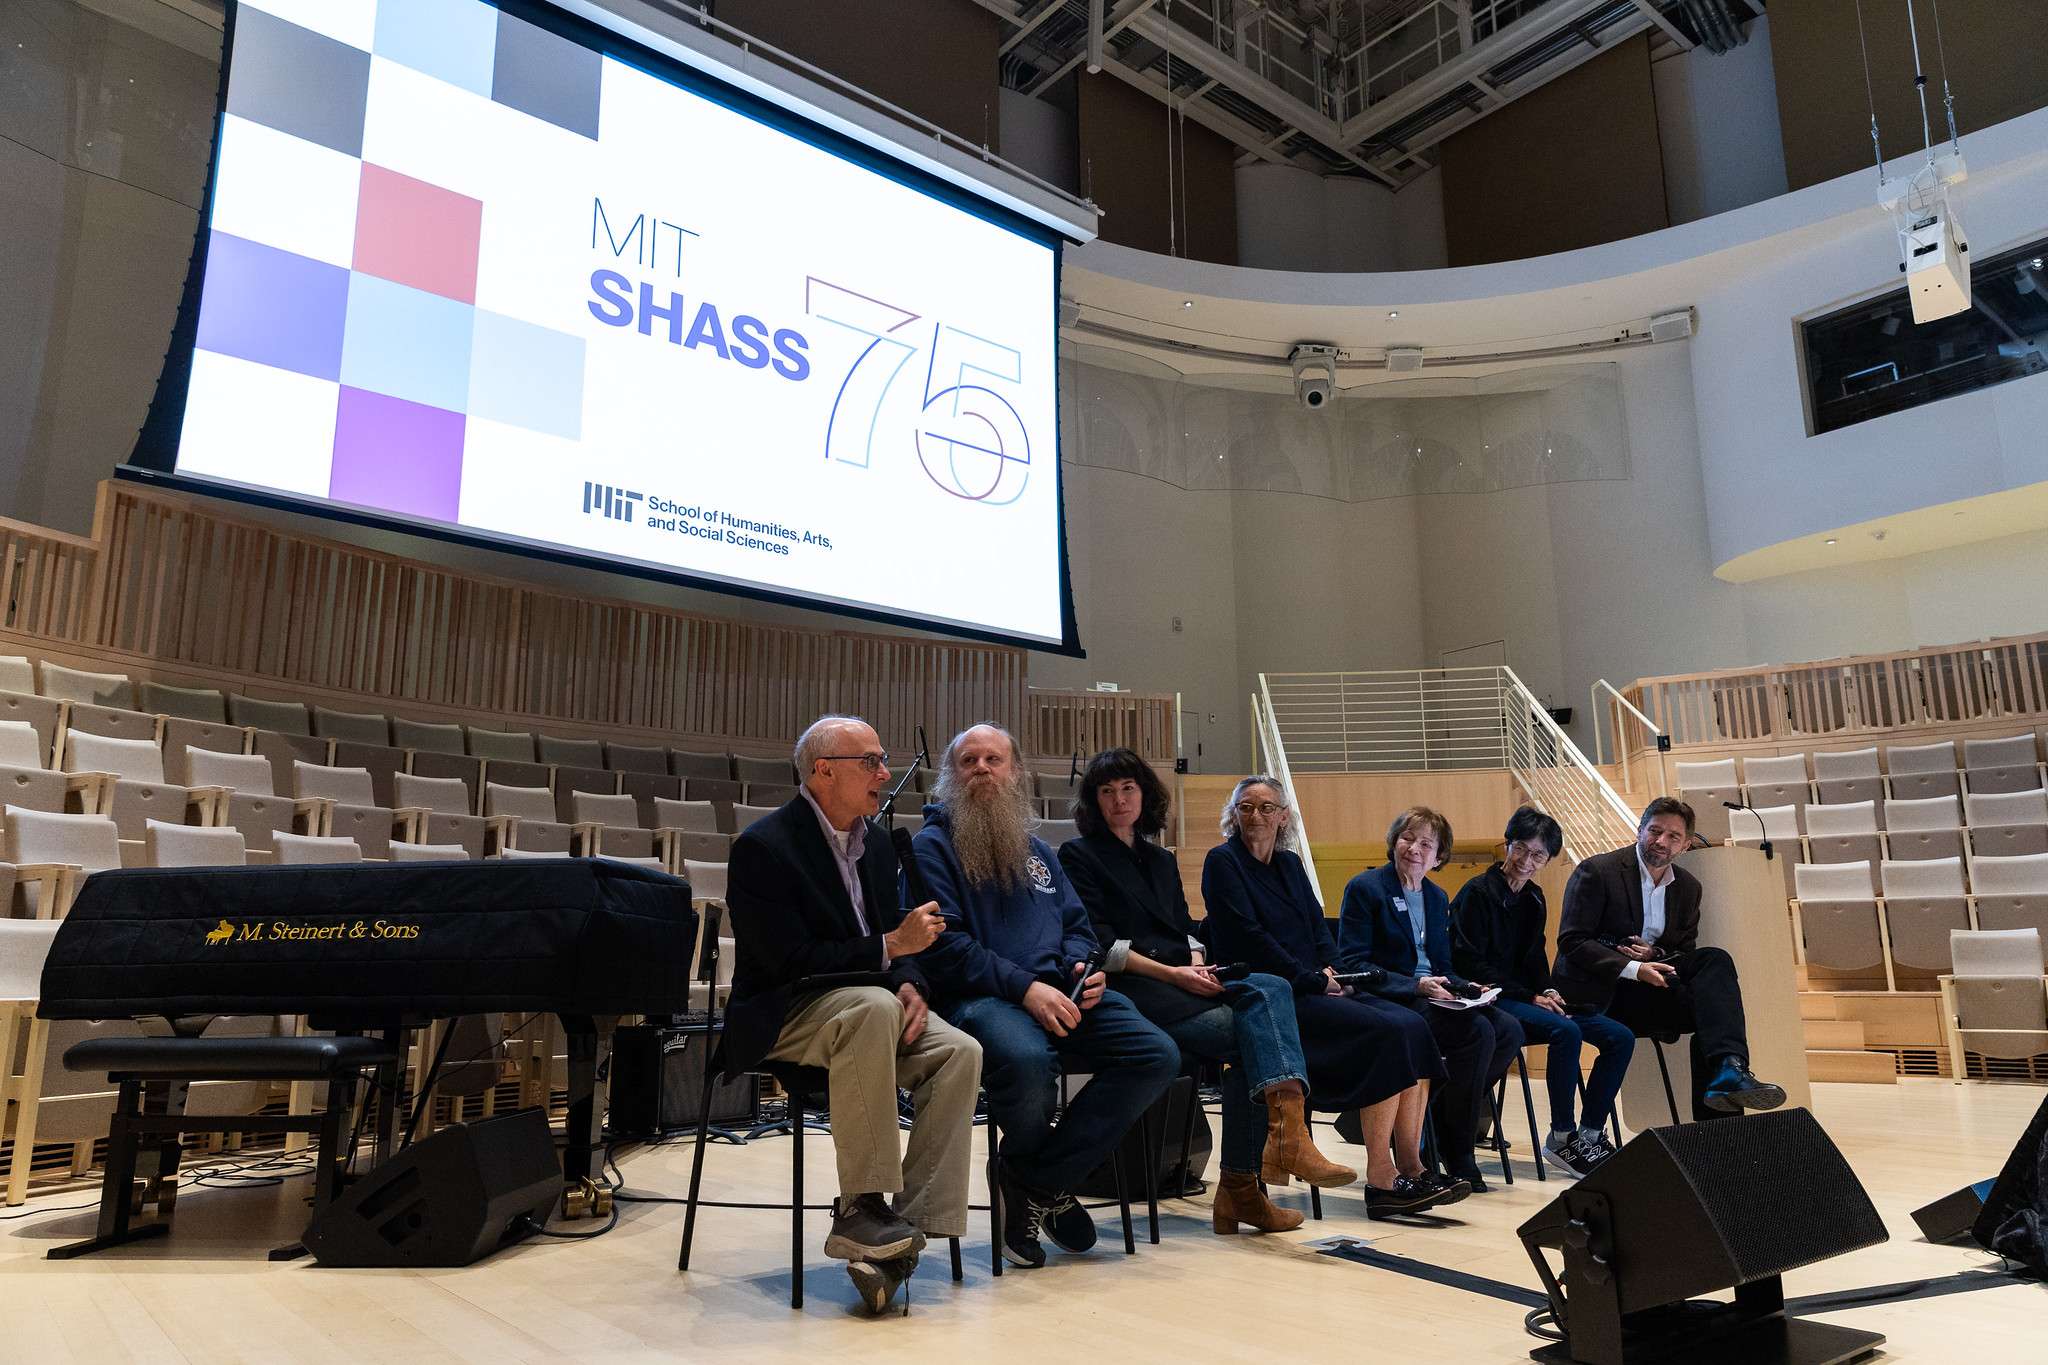
During the School of Humanities, Arts, and Social Sciences’ 75th Anniversary Symposium, President Sally Kornbluth said “MIT has never needed your particular insight and guidance more than we do now.”
MIT News · Artificial Intelligence· news.mit.eduOct 23, 2026
Assistant Professor Benjamin Lindquist studies how engineers deliberately injected randomness into early AI, giving rise to deep-learning models that sometimes hallucinate.
MIT News · Artificial Intelligence· news.mit.eduOct 22, 2026
“X-Hinges” helps design and 3D print items like lamps and gloves with an interactive twist: automatically embedded sensors that perceive and adaptively respond to human contact.
We use cookies to run the site and, with your consent, for analytics and to show ads.
See our Cookie Policy.