Fly-by-Code: Embodied Coding Agents for Aerial Manipulation with Active Visual and Physical Feedback
Jaewoo LeeJeongyeon SeoSihyun ChoGyeongrak ChoeYutong WangBavin SaravananJia-Bin HuangFurong HuangSebastian SchererGuanya ShiH. Jin KimSeungjae LeeDongjae Lee
Oct 2026
Machine LearningComputer VisionRobotics
Abstract
Embodied coding agents construct robot policies from natural-language instructions by generating executable programs and refining them from execution feedback. This refinement assumes that execution feedback reveals whether the task succeeded and, after a failure, provides sufficient evidence to guide program revision. Aerial manipulation violates this assumption in two ways. Payload constraints restrict onboard camera coverage and leave task-critical outcomes outside the robot's view (partial observability), while strong dynamic coupling and limited control margins make physical interactions fragile (limited interaction robustness) and leave failure causes unresolved. Re-examining the same feedback cannot recover observations that were never collected or separate failure causes that the available evidence does not distinguish. To acquire this missing evidence, we introduce Active Feedback (AF), an active "View and Probe" framework. When execution feedback leaves unresolved questions, the agent synthesizes a separate diagnostic program that runs in simulation to inspect unseen outcomes from informative viewpoints (View) or test hypotheses about failure causes through targeted physical interactions (Probe). Across six simulated aerial manipulation tasks with 60 trials per condition, AF reduces false completion declarations from 25 to 5 and raises final task success from 31.7% to 75% compared with terminal feedback under the same coding-agent configuration and task-execution limit. Using shared robot APIs, task programs refined with AF in simulation run on a physical aerial manipulator without task-program source-code modification and complete multi-stage manipulation tasks in the real world. These results show that executable diagnosis fills gaps in execution feedback for embodied coding agents, improving both completion assessment and program refinement in aerial manipulation.
This publication proposes a definition and a classification of agile software development approaches and analyses ten software development methods that can be characterized as being "agile" against the defined criterion.
P. Abrahamsson, O. Salo, Jussi Ronkainen et al.· arXiv.org· 727 citations· ⚡54
The study shows that agile practices improve both informal and formal communication, but indicates that, in larger development situations involving multiple external stakeholders, a mismatch of adequate communication mechanisms can sometimes even hinder the communication.
M. Pikkarainen, Jukka Haikara, O. Salo et al.· Empirical Software Engineeri...· 401 citations· ⚡48
The results indicate that software engineering work practices are chosen opportunistically, adapted and configured to provide value under the constrains imposed by the startup context.
Nicolò Paternoster, Carmine Giardino, M. Unterkalmsteiner et al.· Information and Software Tec...· 394 citations· ⚡54
The possibility of inferring high-dimensional data inference in a model that consists of a prior and an auxiliary differentiable constraint given some additional information is considered, thereby allowing a range of potential applications in adapting models to new domains and tasks.
Alexandros Graikos, Esmeralda S. Whitammer, N. Jojic et al.· Neural Information Processin...· 316 citations· ⚡15
It is proved that any global minimizer of the trajectory balance objective can define a policy that samples exactly from the target distribution, and empirically demonstrate the benefits of the trajectories balance objective for GFlowNet convergence, diversity of generated samples, and robustness to long action sequenc...
Esmeralda S. Whitammer, Moksh Jain, Emmanuel Bengio et al.· Neural Information Processin...· 302 citations· ⚡60
Exploring how generative AI could make machine vision more accessible to businesses. The post GenEye in a Box: Making Machine Vision Something You Can Just Ask For appeared first on GPT-Lab.
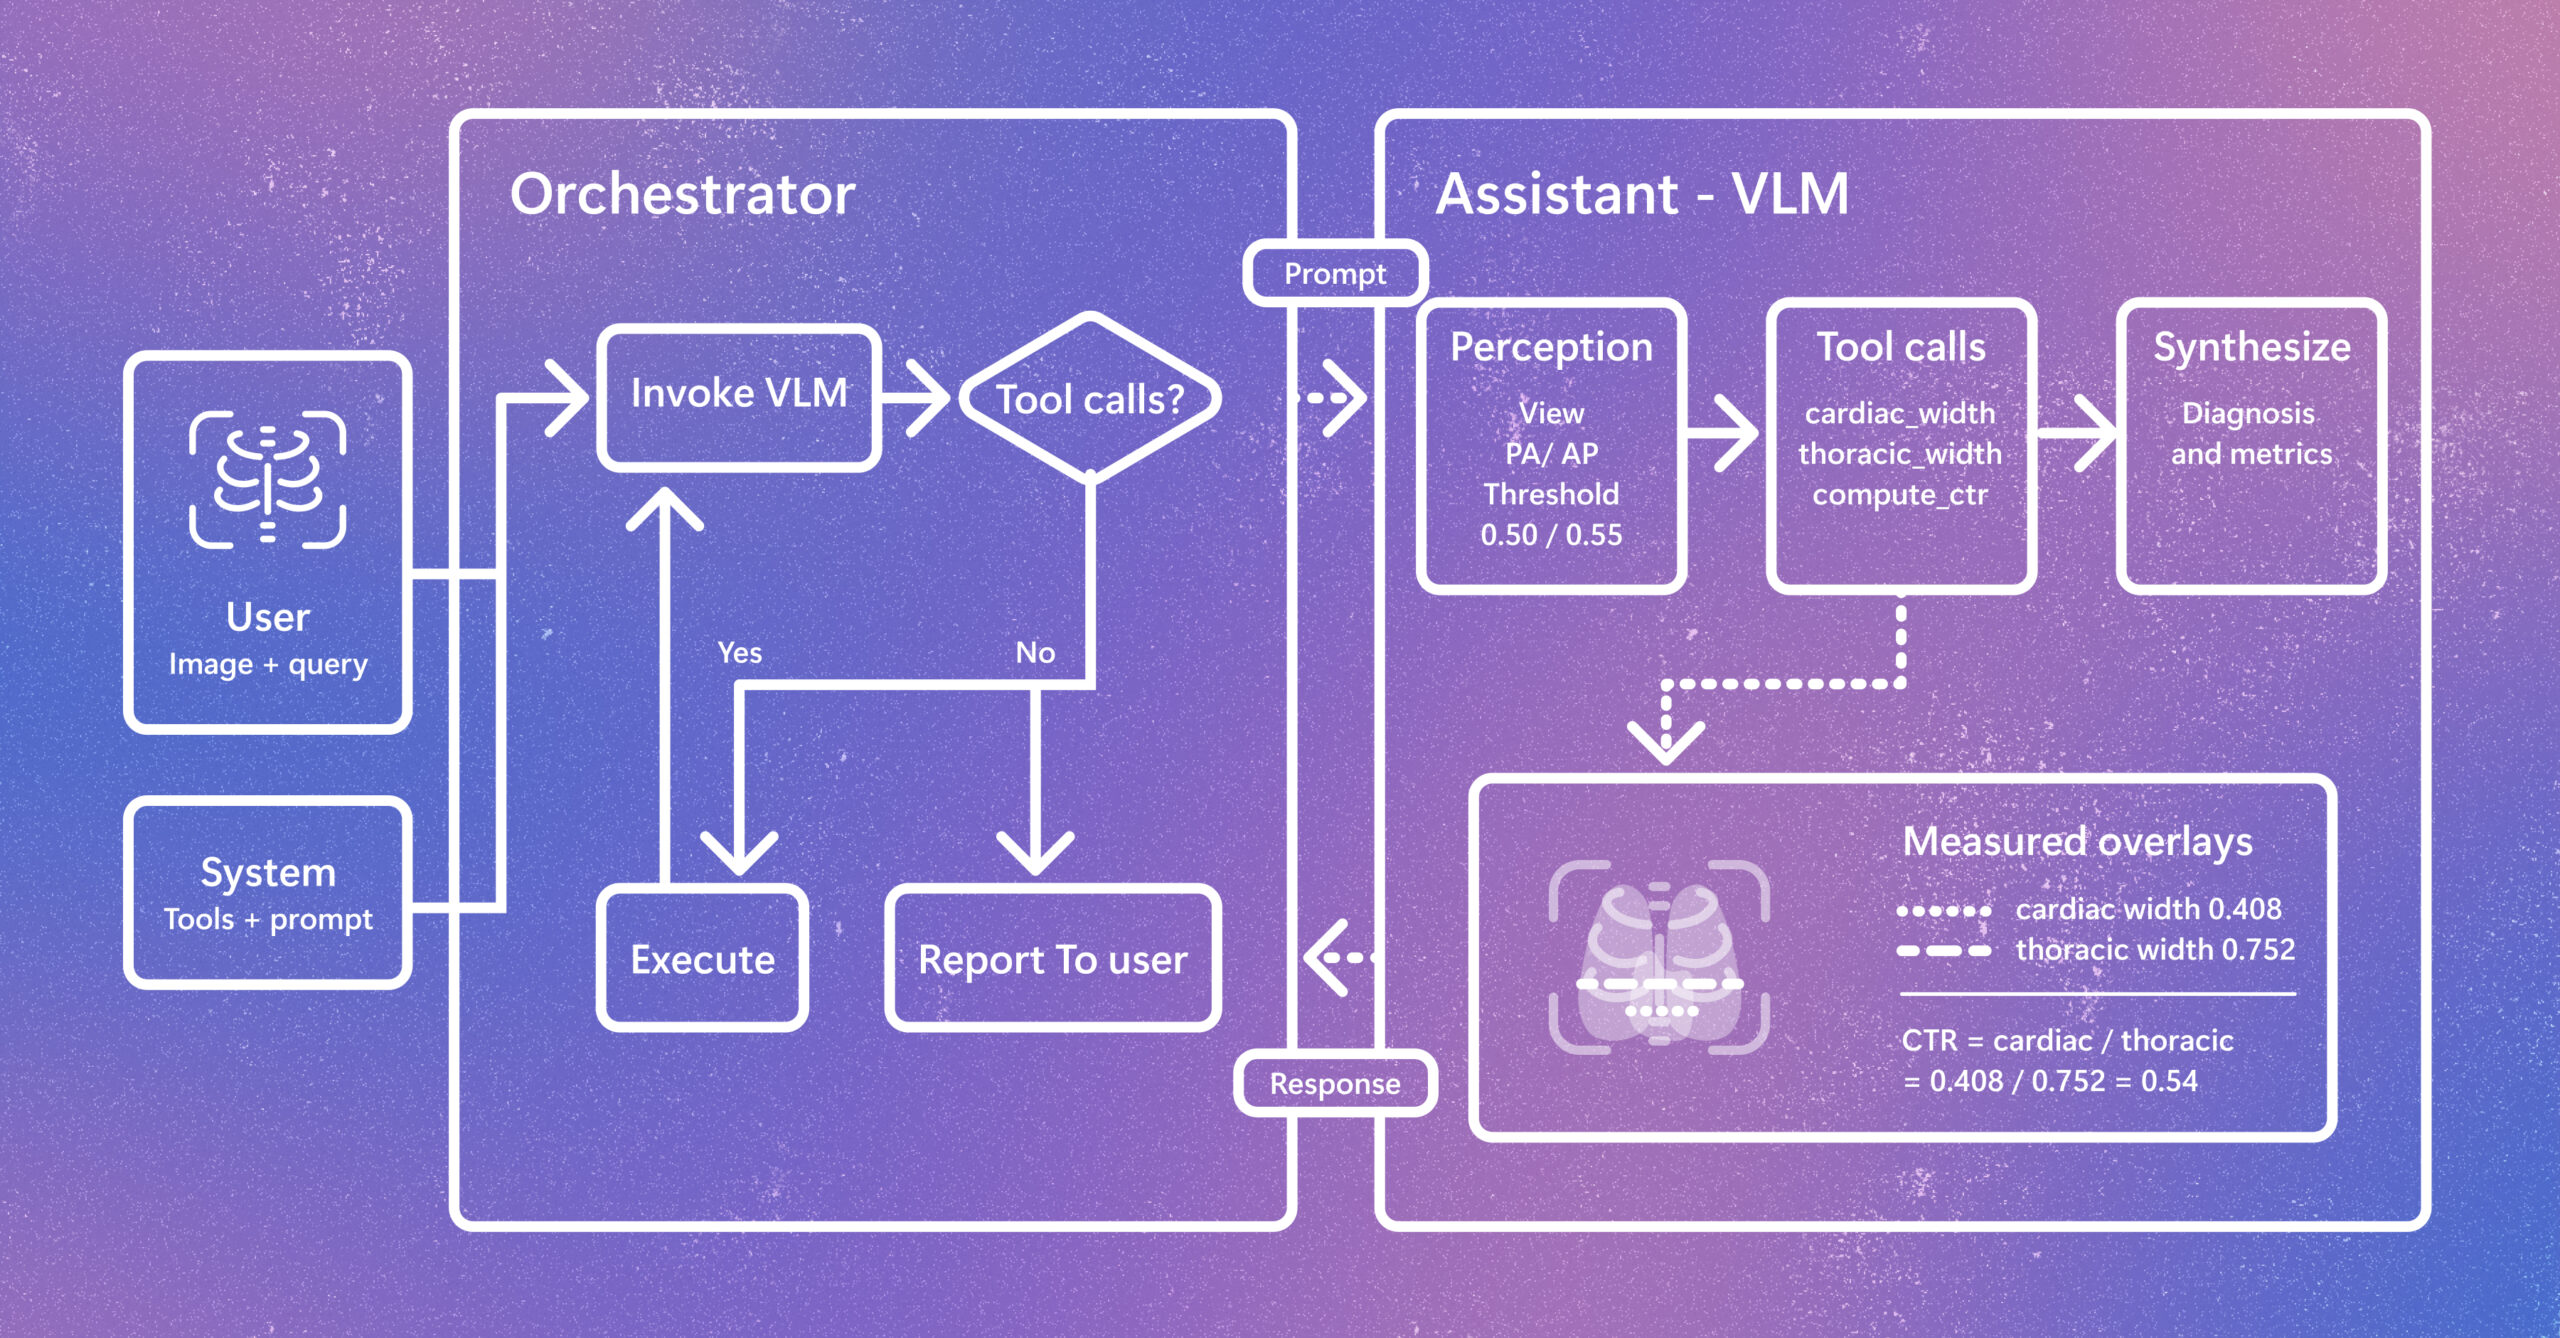
Radiology AI is evolving beyond report generation. CARE-X explores a unified approach that combines flexible reasoning, calibrated predictions, and measurement-based tools for chest X-ray interpretation. The post Introducing CARE-X: Towards Clinically Useful Radiology VLMs with Auxiliary Supervision, Reward-Aligned Learning, and Tool-Augmented Measurement appeared first on Microsoft Research.