Training robust social-navigation policies requires simulators with diverse scene layouts, terrain, and human motion, but constructing such environments and specifying pedestrian behavior is costly. We propose an efficient pipeline that converts ordinary monocular walking videos directly into closed-loop social-navigation training environments in the policy's state space. Our key observation is that local social navigation primarily depends on two types of information: where the robot can traverse and how nearby pedestrians move. We therefore represent the static scene as a metric traversability map, which can be rigidly transformed under counterfactual robot motion, while directly replaying the pedestrian trajectories recovered from the video over time. This abstraction allows us to define the forward dynamics directly in the policy's state space and efficiently simulate counterfactual robot states without reconstructing or rendering photorealistic observations. The resulting policy achieves 81.2% success in the independent Arena benchmark, compared with 75.0% for the strongest baseline, and succeeds in 19/20 real-robot trials without policy fine-tuning. Project page: https://jiaming.im/VideoSocNav
This publication proposes a definition and a classification of agile software development approaches and analyses ten software development methods that can be characterized as being "agile" against the defined criterion.
P. Abrahamsson, O. Salo, Jussi Ronkainen et al.· arXiv.org· 727 citations· ⚡54
The study shows that agile practices improve both informal and formal communication, but indicates that, in larger development situations involving multiple external stakeholders, a mismatch of adequate communication mechanisms can sometimes even hinder the communication.
M. Pikkarainen, Jukka Haikara, O. Salo et al.· Empirical Software Engineeri...· 401 citations· ⚡48
The results indicate that software engineering work practices are chosen opportunistically, adapted and configured to provide value under the constrains imposed by the startup context.
Nicolò Paternoster, Carmine Giardino, M. Unterkalmsteiner et al.· Information and Software Tec...· 394 citations· ⚡54
The possibility of inferring high-dimensional data inference in a model that consists of a prior and an auxiliary differentiable constraint given some additional information is considered, thereby allowing a range of potential applications in adapting models to new domains and tasks.
Alexandros Graikos, Esmeralda S. Whitammer, N. Jojic et al.· Neural Information Processin...· 316 citations· ⚡15
It is proved that any global minimizer of the trajectory balance objective can define a policy that samples exactly from the target distribution, and empirically demonstrate the benefits of the trajectories balance objective for GFlowNet convergence, diversity of generated samples, and robustness to long action sequenc...
Esmeralda S. Whitammer, Moksh Jain, Emmanuel Bengio et al.· Neural Information Processin...· 302 citations· ⚡60
Exploring how generative AI could make machine vision more accessible to businesses. The post GenEye in a Box: Making Machine Vision Something You Can Just Ask For appeared first on GPT-Lab.
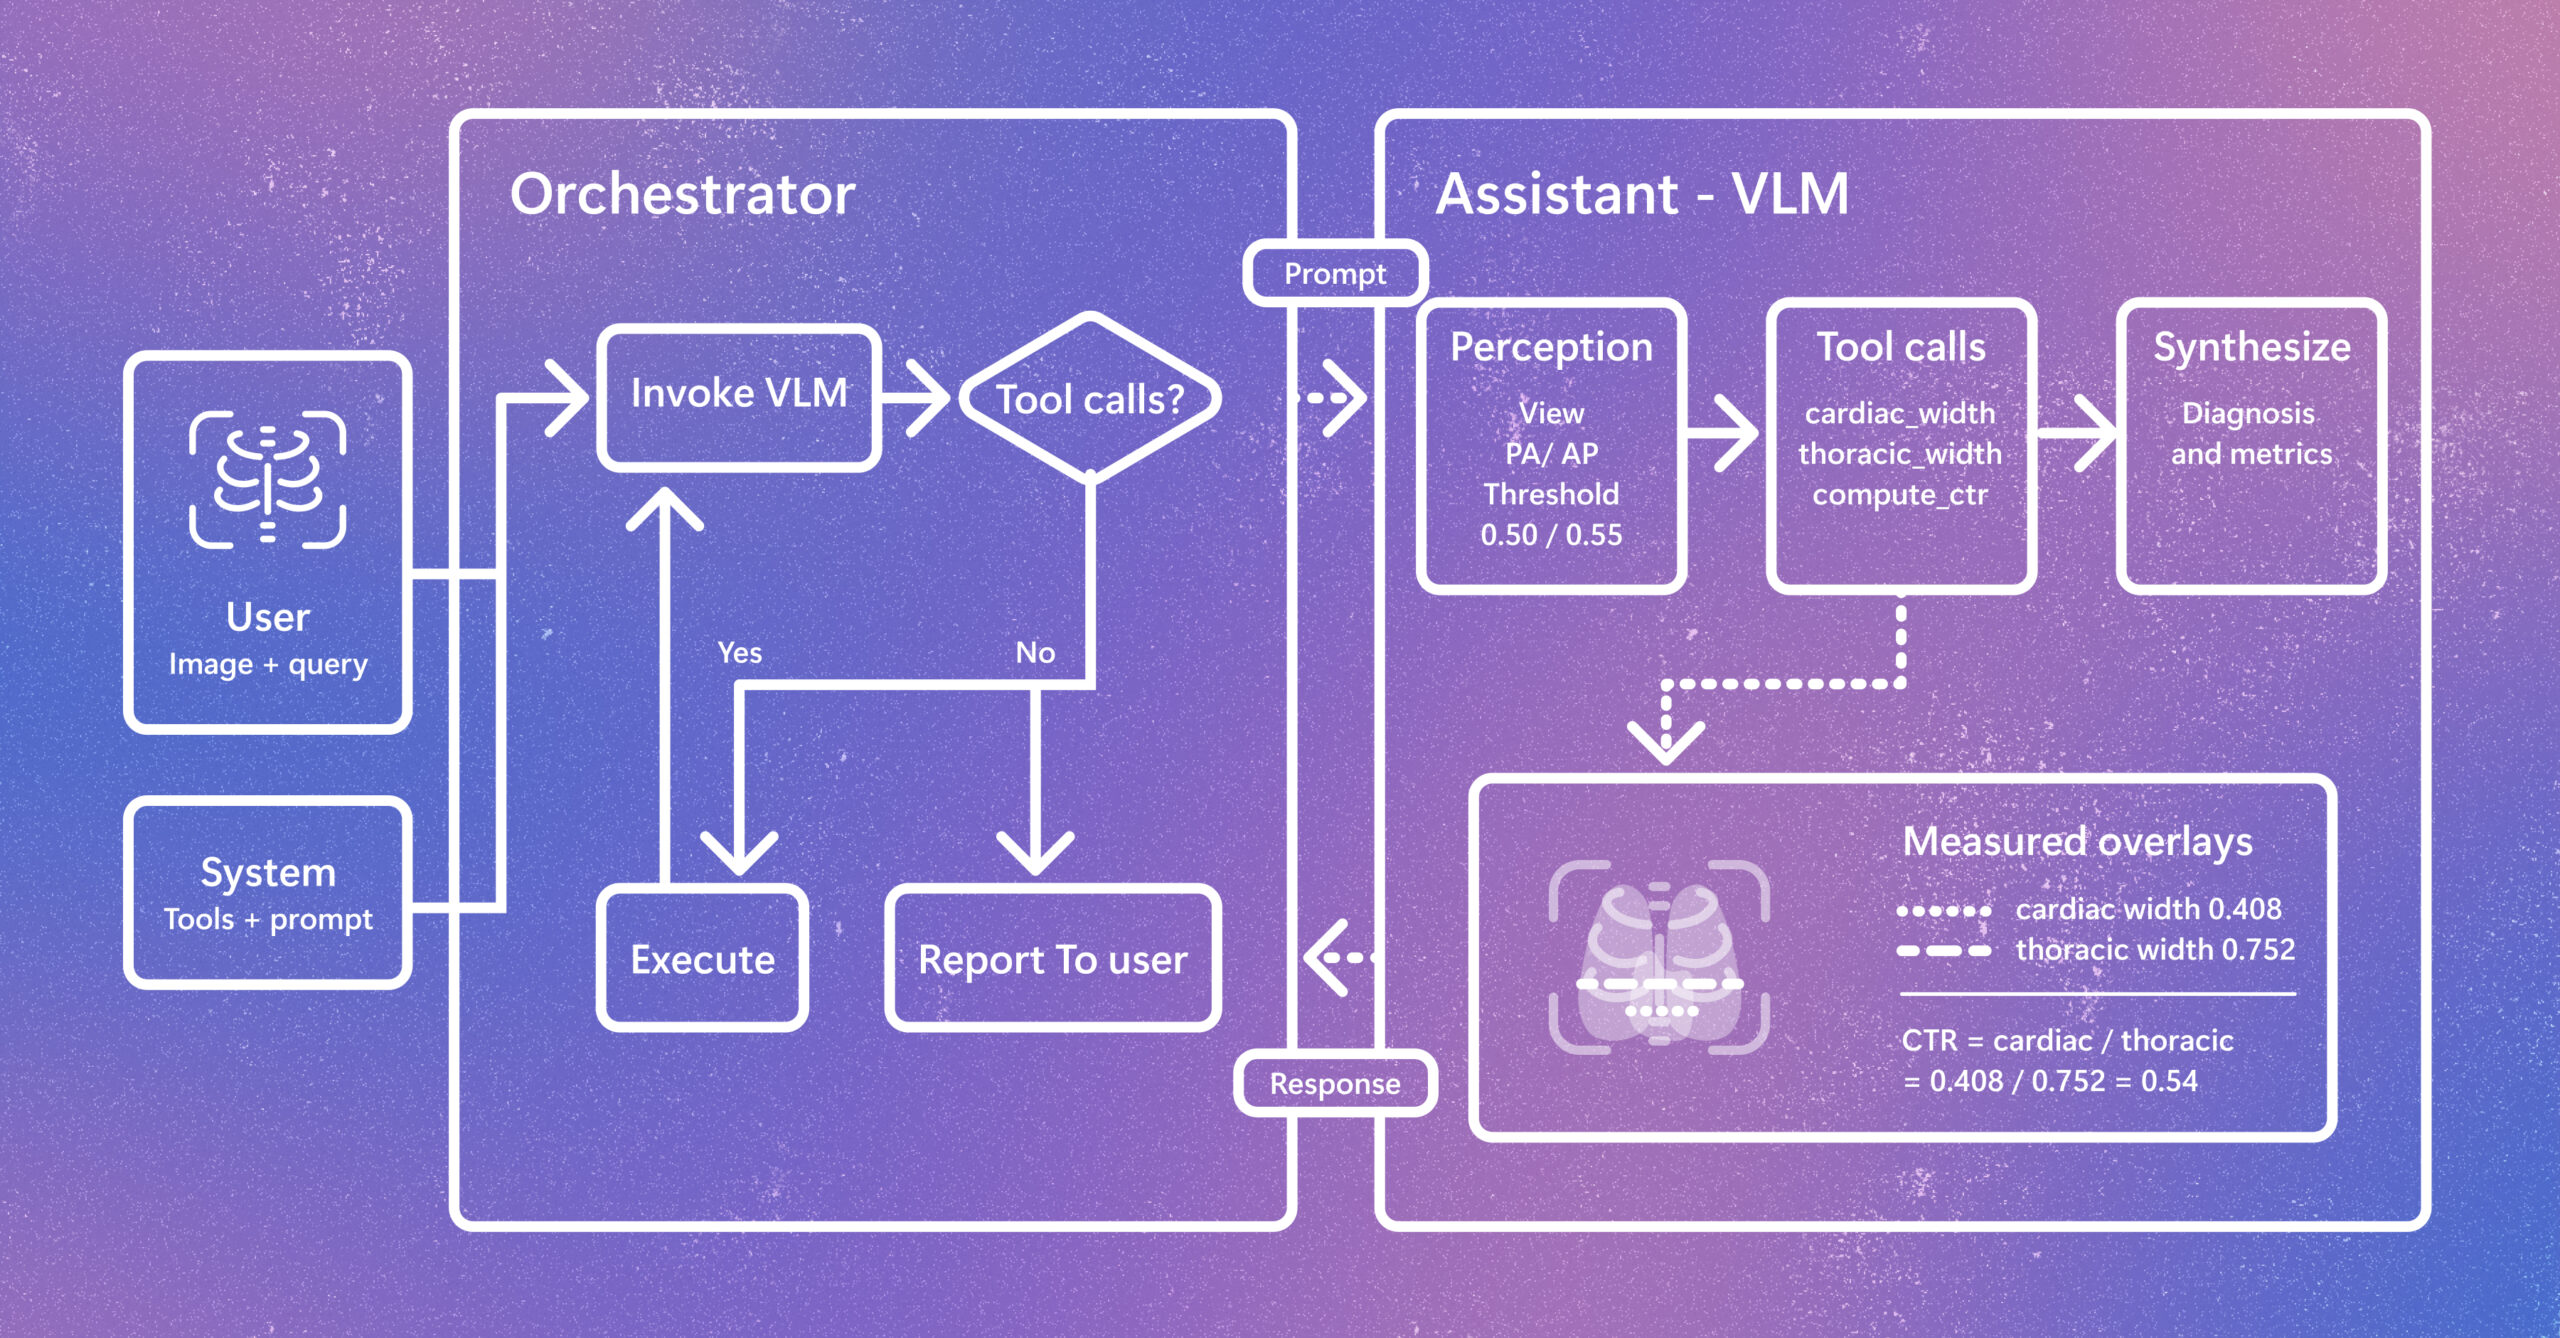
Radiology AI is evolving beyond report generation. CARE-X explores a unified approach that combines flexible reasoning, calibrated predictions, and measurement-based tools for chest X-ray interpretation. The post Introducing CARE-X: Towards Clinically Useful Radiology VLMs with Auxiliary Supervision, Reward-Aligned Learning, and Tool-Augmented Measurement appeared first on Microsoft Research.